Renderer
How it looks
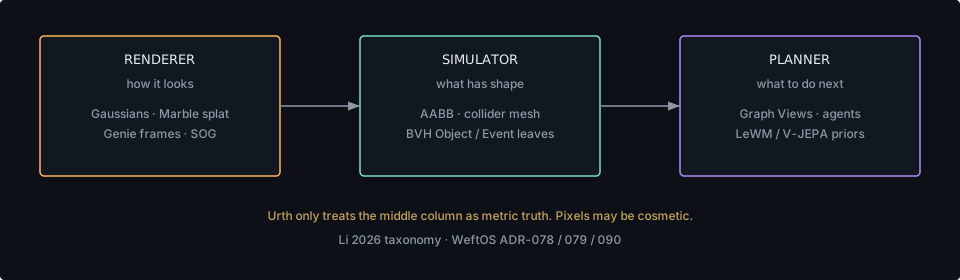
Gaussian splats, Marble exports, Genie frames, SOG. Pretty, fast, often fake beyond the capture frustum.
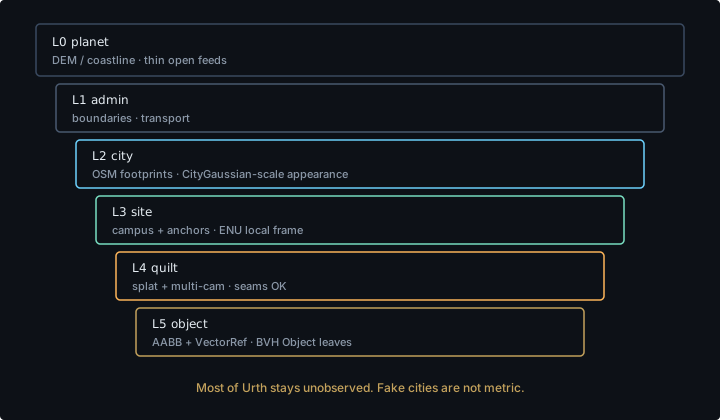
WeftOS already indexes where, similar, and why. Urth densifies the planet only where we observe.
BVH · HNSW · Graph Views · ADR-056 / 078 / 079
↓ scroll — renderer, simulator, planner
In 2026 “world model” names three jobs. WeftOS keeps them apart: appearance may be generated; metric shape lives in the BVH; plans ride Graph Views and optional LeWM. Generative fill is never treated as surveyed truth.
Gaussian splats, Marble exports, Genie frames, SOG. Pretty, fast, often fake beyond the capture frustum.
AABBs, collider meshes, Object vs Event leaves. This is the only column Urth treats as metric.
Agents, fusion graphs, latent predictors. Useful priors — never the world source of truth.
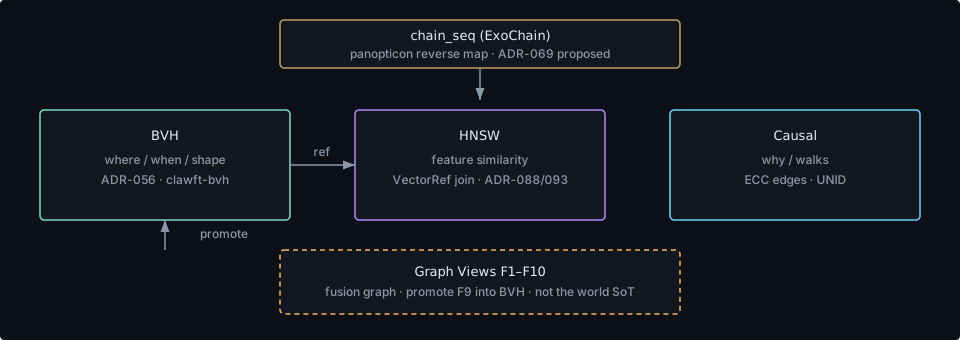
ECC already had HNSW, causal edges, and UNID lookup. ADR-056 added the missing fourth: geometric overlap. They compose; they do not compete.
where / when / shape
looks like / means like
why / who cites whom
fusion, then promote
Humans, Spark-style viewers, Agent Workspace backdrops. Marble Gaussians belong here. Optional cosmetic fill must be labeled non-metric.
Object vs Event, AABB, chain evidence. Marble collider meshes rhyme with this column. W1 export exists; live publish does not.
Every spatial payload may carry an optional VectorRef. Default is none — pure geometry. Feature kNN stays on HNSW. Geometric kNN on the BVH is AABB-center proximity, not cosine. Phase F helpers compose the two without inlining embeddings.
W1 still writes bvh_published: false. Structure extract does not enter the index.
spatial_cli_e2e is ignored. Reattach via SpatialService.
Graph Views research exists; stable components do not yet mint Object leaves.
Region hierarchy and OSM basemap ingest were unchecked on E0.
ADR-069 reverse join by chain_seq is still proposed.
Deferred, not disqualified. HNSW stays primary.
New papers and products since the 0.8 cut. Click a card for the seam. Deep dives live under docs/research/spatial-intelligence-2026/.
World Labs dual export (splats + collider mesh) is the commercial form of ADR-078. Atlas (2026-09-01) is an omni camera-controlled model. Spark 2.0 streams 3DGS with LOD.
Interactive video worlds. Minutes of consistency, not a surveyed planet. May feed LeWM rollouts. Not Urth geometry.
Feed-forward reconstruction can sit before overnight COLMAP. SpatialLM proposes indoor layout from noisy RGB video — a W1 layout proposer with vector: none.
Floor → room → object graphs. Embeddings stay on VectorRef / HNSW. Geometry stays in the BVH. Promote, do not flatten.
Large-scale splat LOD is the appearance twin of Urth L2–L4 and region-sharded BVH. One planetary Gaussian train is forbidden.
Latent predictive WM. Confirms ADR-090: optional sub-layer. Dense features may become a visual HNSW namespace.
rUv typed twin + provenance cards over a splat. Geometry SoT remains BVH, not CSI occupancy.
Astronex-World, Matrix-Game 3.0, HY-World, Yume. Do not pick a champion this cycle.
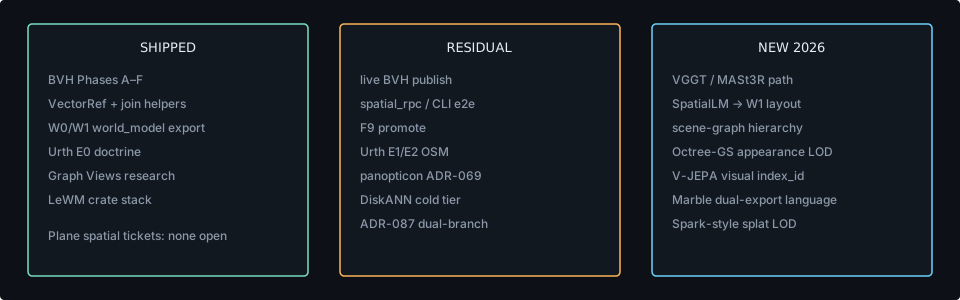
The spatial-index decision is closed. The work left is publish, promote, and ingest — plus a 2026 reconstruction stack that can feed the same leaves.
weftos.weavelogic.ai/urth-spatial · 0.8-metaharness · 2026-09-21